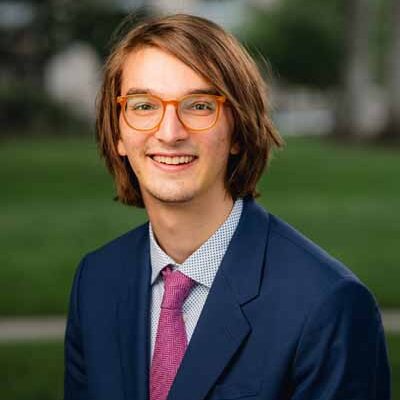
Trey Davis
MIT Department:
Aeronautics and Astronautics
Faculty Mentor:
Andreea Bobu
Research Supervisor:
Nathan Dennler
Undergraduate Institution:
University of Michigan
Biography
Trey Davis studies how robots can work with creatives. As an artist working primarily with ceramics and other sculptural media, he uses his robotics major at the University of Michigan to better understand the animosity his community feels toward AI development. At Michigan, he works with Dr. Patrícia Alves-Oliveira to create robotic assistants that leverage creative psychology to scaffold thinking through thoughtful questions. At MIT, he is studying robot learning using multimodal inputs, with an eye toward applying similar algorithms to create robots that adapt to highly variable artist preferences. He believes that in understanding how robots can fit into the creative process, we come closer to understanding how we can retain our humanity when working with technology. In his PhD, he aims to challenge his understanding of these questions and prompt his discipline to think more critically about the proper role of robotics in future society.
Voice Affect Co-Personalization for Robot Preference Learning
Trey Davis1,2, Nathaniel Dennler2 and Andreea Bobu2
1Department of Robotics, University Michigan – Ann Arbor
2Department of Aeronautics and Astronautics, Massachusetts Institute of Technology
In order for robots to work effectively with humans, they need to adapt to a range of human preferences. Yet, real human feedback is limited and ambiguous, making efficient adaptation a core challenge for preference learning. The emotional, or affective, component of speech is an implicit and useful feedback signal for robot learning. Yet, integrating voice affect into an online robot learning framework remains under-explored. Through the analysis of voice data in a previous robot learning experiment, we found that voice affect is situational, dependent on the user and task framing. We further hypothesize that humans adapt their affect throughout a task to elicit better performance from the robot. Bringing those insights into voice-based learning systems, we formulate two algorithms that incorporate vocal affect into a collaborative robot task. We test these algorithms and our hypothesis in a pilot user study. While the existing understanding of voice affect frames it as a hidden ground truth to be uncovered by robots, we expect to see more efficient use of vocal feedback by conceptualizing the decoding of this signal as a collaborative human-robot effort to construct a shared communication channel.